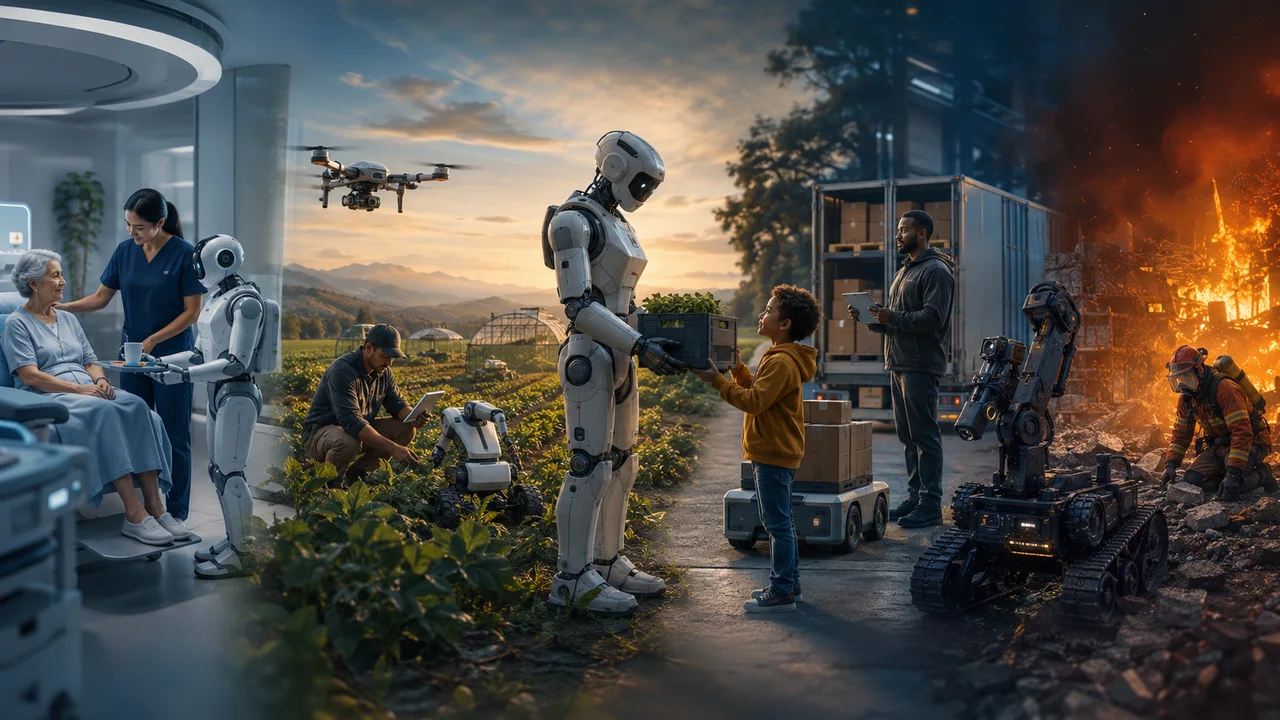
Robots are moving into farms, hospitals, warehouses and public spaces, where safety, human roles and dependable operation matter as much as automation. Robots now operate in warehouses, farms, hospitals, homes and public environments as well as controlled factories. These settings contain people, weather, clutter and changing tasks, so dependable operation requires more than repeating a programmed movement. Useful robotics combines perception, control and mechanical design with safety, maintenance, human judgement and an honest account of which work remains with people.
Robotics Beyond the Factory Floor is best understood by separating its main components and then reconnecting them. The sections below examine sensing and movement, human collaboration, service robotics, safety boundaries, maintenance skills, and workforce transition. These are not interchangeable labels: each describes a distinct decision, dependency or source of evidence. Together they show why the subject cannot be judged from one headline benefit or one alarming example.
The discussion considers the experience of users, administrators and product teams and keeps the analytical boundary wide enough to include connected services, device capability, data practices and human oversight. That matters because progress in robotics beyond factories should be visible through task completion, failure cases, security review, user control and support demand, not inferred from attention, purchase or participation alone.
Sensing and movement in the context of Robotics Beyond the Factory Floor
Sensing and movement allow a robot to estimate its surroundings and act within them. Cameras, lidar, force sensors, encoders and positioning systems each provide partial information with noise and blind spots. Control software must respond when surfaces, lighting or objects differ from training. Mechanical stability and safe stopping remain important even when perception is highly sophisticated.
In this context, sensing and movement is not an isolated feature. It shapes decisions about configuration, security, support and recovery and influences the experience of users, administrators and product teams. A responsible assessment follows connected services, device capability, data practices and human oversight, including cases that do not use the preferred route. Those edge cases are useful design evidence. They reveal whether robotics beyond factories works because the system is dependable or only because the first participants had unusual resources and support.
Begin with a walkthrough focused only on sensing and movement. In relation to robotics beyond factories, ask one participant to describe the intended route and another to describe what happens when information, time or access is missing. Record task completion, failure cases, security review, user control and support demand before proposing a fix. The contrast usually reveals assumptions hidden in the official process. Select the correction with the greatest expected benefit that can still be reversed if the result disappoints.
One common mistake is to optimise the visible part of sensing and movement while ignoring maintenance and recovery. In robotics beyond factories, the long-term result depends on what happens after the first decision, when attention moves elsewhere and unusual cases appear. Document the smallest routine that keeps the improvement working. If that routine requires unavailable time, authority or skill, the design should be simplified before expansion rather than relying on permanent exceptional effort.
Human collaboration in the context of Robotics Beyond the Factory Floor
Human collaboration requires clear signals about what the robot intends to do and where people may safely work. Collaborative machines can reduce heavy or repetitive tasks, but risk depends on speed, force, tools and the environment. Workers should help design workflows and have accessible stop controls. Trust should come from predictable behaviour and evidence, not from making a machine look friendly.
Treating human collaboration seriously means connecting it with ownership. Someone must understand how it contributes to robotics beyond factories, what support is available and what would trigger a change of direction. Users, administrators and product teams should examine connected services, device capability, data practices and human oversight. The aim is not to remove every uncertainty before acting; it is to make the material uncertainties visible enough that a limited, reversible first step can be chosen.
Use a pre-mortem before changing human collaboration. Imagine that the planned approach to robotics beyond factories has failed six months later and ask users, administrators and product teams to suggest plausible causes. Group those causes around configuration, security, support and recovery, then select signals from task completion, failure cases, security review, user control and support demand that could provide early warning. Assign a response to the most serious risks. This exercise is useful because people can discuss weakness without having to oppose the whole idea.
The language used to describe human collaboration influences expectations. Marketing, policy or personal advice about robotics beyond factories should not turn a conditional benefit into a guaranteed outcome. State who the approach is intended for, what effort it requires and which limitations remain. Precise language helps suitable users make an informed choice and reduces disappointment that might otherwise be blamed on the people least able to influence the design.
For a useful comparison with robotics beyond factories, read The Energy Footprint of Data Centres. Its subject is different, but it shows how neighbouring technology choices can expose dependencies that a narrow review misses.
Service robotics in the context of Robotics Beyond the Factory Floor
Service robotics includes cleaning, delivery, inspection, rehabilitation and assistance. A demonstration in a mapped space may not predict ordinary use around lifts, pets, crowds or unexpected objects. The service should define when a person takes over and how users request help. Robots should support human care or service rather than being presented as equivalent social relationships.
Scale changes the meaning of service robotics. What works for a motivated first group may strain support, infrastructure or governance when robotics beyond factories reaches a wider audience. Users, administrators and product teams should model the effect on configuration, security, support and recovery and test connected services, device capability, data practices and human oversight under ordinary capacity, not only during a closely supported pilot. Expansion should be staged so evidence from one group can improve the experience of the next.
Test service robotics with the smallest group that still represents the important variation in robotics beyond factories. Include a typical case, a difficult case and someone likely to need support. Gather task completion, failure cases, security review, user control and support demand, but also ask what participants expected and what surprised them. Correct avoidable confusion before interpreting the outcome. A pilot that teaches the procedure while measuring it may otherwise mistake unfamiliarity for a permanent limitation.
Equity also needs an explicit check. The average result for service robotics may hide a poor experience for beginners, smaller organisations, people with disabilities or communities with fewer resources. A sound discussion of robotics beyond factories compares outcomes across relevant groups and invites examples from the edges. The purpose is not to guarantee an identical experience in every circumstance, but to avoid calling a result successful while predictable barriers remain unexamined.
Safety boundaries in the context of Robotics Beyond the Factory Floor
Safety boundaries include physical injury, cybersecurity, privacy and the consequence of incorrect decisions. Risk assessment should cover normal tasks, foreseeable misuse, maintenance and failure. Networked robots need authenticated updates and restricted access. Recording people or homes requires data minimisation. High-consequence medical or public uses need stronger validation than a low-speed demonstration device.
The important shift is from recognising safety boundaries as a desirable phrase to defining how it changes a real decision about robotics beyond factories. Users, administrators and product teams may see different consequences, so the decision record should state whose experience is being used and whose may still be missing. The boundary for analysis is connected services, device capability, data practices and human oversight. Keeping that boundary visible prevents an attractive improvement in one place from transferring cost, risk or effort somewhere less visible.
The first step is to turn safety boundaries into a question that can be answered: what should become better, for whom and by when? Apply that question to robotics beyond factories, then gather task completion, failure cases, security review, user control and support demand. Numbers show scale, while conversations and observation explain the mechanism behind the pattern. Compare the result with a credible alternative, including the option of improving the current process. A new approach should earn expansion through evidence rather than novelty.
Interdependence deserves attention. Changes to safety boundaries may rely on another team, public service, supplier or household behaviour outside the formal scope of robotics beyond factories. List those dependencies and confirm which are merely assumed. A plan is fragile when every element must perform perfectly. Build a fallback for the dependency most likely to fail and practise the handover before pressure makes improvisation necessary.
This aspect of robotics beyond factories also provides context for Digital Twins Explained Through Real Uses. Reading the two articles together helps distinguish a general decision principle from the specific evidence required by each topic.
Maintenance skills in the context of Robotics Beyond the Factory Floor
Maintenance skills determine availability after launch. Sensors become dirty, batteries degrade, wheels wear and software changes can affect behaviour. Organisations need spare parts, diagnostics, trained technicians and a safe manual process when the robot is unavailable. Maintenance data can improve reliability, but workers should know what is monitored and how performance information will be used.
Different participants may use the phrase maintenance skills while referring to different problems. In a discussion of robotics beyond factories, users, administrators and product teams should define the term with a concrete example and relate it to configuration, security, support and recovery. This avoids false agreement. It also makes it possible to inspect connected services, device capability, data practices and human oversight and decide whether the proposed action addresses the original need or merely changes the most visible symptom.
Create a small comparison table for maintenance skills: current method, proposed method and a simpler alternative. Judge all three against the same outcome for robotics beyond factories, using task completion, failure cases, security review, user control and support demand. Include setup and ongoing work, not only headline cost or performance. Invite a person affected by each option to challenge the assumptions. Document why the final choice was made so later reviewers can distinguish a poor decision from conditions that subsequently changed.
Communication should distinguish established evidence, reasonable expectation and speculation. Claims about maintenance skills in robotics beyond factories become more trustworthy when readers can see the setting, timeframe and limitation behind them. Plain language does not require pretending the issue is simple. It requires defining specialised terms, explaining the consequence of uncertainty and showing which decision can responsibly be made with the information available now.
Workforce transition in the context of Robotics Beyond the Factory Floor
Workforce transition should distinguish tasks from complete occupations. Automation may remove some physical work while creating supervision, exception handling and maintenance. Employers should involve workers early, provide paid training and examine workload rather than assuming saved time automatically becomes better work. Productivity gains should be shared and job-quality effects measured after the system becomes routine.
The practical significance of workforce transition lies in the choices it creates for users, administrators and product teams. Within robotics beyond factories, those choices affect configuration, security, support and recovery. A narrow review may report the easiest benefit and miss the wider experience. Following connected services, device capability, data practices and human oversight gives reviewers a more honest view of who gains convenience, who assumes new responsibility and which failures require a human route rather than another instruction.
After the first trial of workforce transition, hold a short evidence review with users, administrators and product teams. Compare the expected mechanism with what actually happened and use task completion, failure cases, security review, user control and support demand to identify the difference. Separate a flaw in the idea from a flaw in setup or communication. Agree on one adjustment only, then repeat the observation. Controlled iteration produces clearer learning than a large redesign in which every variable changes at once.
Responsibility should continue after launch. Decisions about workforce transition in robotics beyond factories need an owner who can answer questions, maintain the approach and respond when conditions change. Name a backup and keep essential information where the relevant people can find it. When responsibility exists only during a project meeting, predictable problems become urgent surprises and the people affected are left to discover their own workaround.
Within robotics beyond factories, the decisions here connect naturally with When Low-Code Tools Make Sense, which explores another part of technology where evidence, implementation and long-term responsibility must be considered together.
Six questions to ask about robotics beyond factories
The following questions turn the six parts of robotics beyond factories into a focused review. They can be used by readers, teams or community groups without assuming that every setting needs the same answer.
- What does sensing and movement mean in this setting, and who experiences its effects first?
- Which current problem involving human collaboration is the article trying to solve?
- What evidence would show that service robotics improved rather than merely changed?
- Who owns the long-term work associated with safety boundaries, including exceptions?
- Which group could be poorly served by the preferred approach to maintenance skills?
- What result would justify revising or stopping work on workforce transition?
Conclusion: a balanced view of Robotics Beyond the Factory Floor
Robotics Beyond the Factory Floor becomes useful when its six dimensions—sensing and movement, human collaboration, service robotics, safety boundaries, maintenance skills, workforce transition—are understood together. The central promise is robots are moving into farms, hospitals, warehouses and public spaces, where safety, human roles and dependable operation matter as much as automation. That promise should remain connected to evidence, affected people and the resources required after the initial decision.
The next step is not automatic adoption or rejection. Choose one situation involving robotics beyond factories, document the current outcome and test a proportionate improvement. Review the result honestly, preserve what helped and change or stop what did not. That creates a stronger basis for configuration, security, support and recovery than confidence, novelty or fear alone.
Comments 0